> For the complete documentation index, see [llms.txt](https://robonation.gitbook.io/robosub-resources/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://robonation.gitbook.io/robosub-resources/section-3-autonomy-challenge/3.2-task-descriptions.md).

# 3.2 Task Descriptions

This section provides details of the tasks in the Autonomy Challenge. Teams are encouraged to develop a strategy approaching these tasks that best suits their vehicle(s).  The launch point, gate, or any of the tasks are placed such that no three elements are along a line.

### Restore and Recovery

A storm swept through the area, leaving behind damaged infrastructure, disrupted communication, and environmental hazards.  Vehicles are deployed to demonstrate how coordinated action can turn disaster into resilience and take on one of two roles: **Survey & Repair** or **Search & Rescue**.

* **Survey & Repair:** Vehicles are deployed for damage assessment to inspect the area and repair infrastructure.
* **Search & Rescue:** Vehicles search the debris armed with supplies to restore safety and functionality.&#x20;

## 3.2.1 Heading Out (Coin Flip)

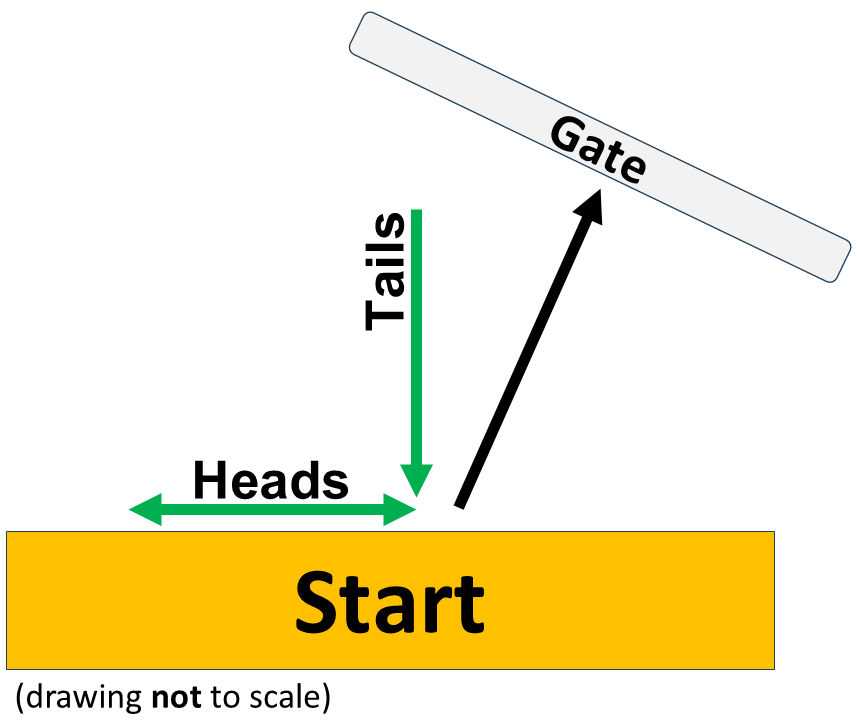
At the start of a run, teams may orient their AUV in any direction from the designated starting location.  All vehicles must begin the run on the surface, and submerge before leaving the start zone. &#x20;

Before the start of a run, and for additional points, teams may request a coin flip which determines the AUV's starting orientation: &#x20;

* If the coin lands on **HEADS**, the AUV is positioned approximately parallel to the gate. &#x20;
* If the coin lands on **TAILS**, the AUV is positioned with its tail approximately facing the gate (the AUV is backward).

  <figure><img src="https://content.gitbook.com/content/26VLfALJrSNXYGtaP3Ke/blobs/DkICLc73pEWvfaa6R26N/Task00_HeadingOut.png" alt="" width="563"><figcaption><p>Figure : Heading Out</p></figcaption></figure>

## 3.2.2 Task 1 - Begin Assessment (Gate)

Head out to assess the environment.&#x20;

The task consists of a gate built from PVC pipe floating just below the surface and moored to the bottom. Surrounding the vertical legs of the pipe are 3-inch wide panels made from **BLACK** and <mark style="color:red;">**RED**</mark> corrugated plastic sheet, attached to make a box around the pipe. On the right-hand side, <mark style="color:red;">**RED**</mark> covers the upper half (Red, Right, Above) and **BLACK** covers the bottom half. On the left-hand side **BLACK** covers the upper half and <mark style="color:red;">**RED**</mark> covers the lower half.&#x20;

The gate is built from PVC pipe and 3-inch boxes made from corrugated plastic sheet. It is buoyant, floating just below the surface and moored to the bottom. The boxes are colored **BLACK** and <mark style="color:red;">**RED**</mark>. <mark style="color:red;">**RED**</mark> is on top on the right-hand side (Red, Right, Above). The AUV can pass through the gate at any depth from the floor to just below the gate.&#x20;

A 2-inch <mark style="color:red;">**RED**</mark> corrugated flat sheet is used to divide the gate in half. An image of a :compass\:/ :hammer\_pick: (**Survey & Repair**) on one side (could be either side), an image of :ring\_buoy:/ :sos: (**Search & Rescue**)on the other side. The AUV chooses a role by passing under a specific side.&#x20;

* **Survey & Repair:** :compass\:/:hammer\_pick:&#x20;
* **Search & Rescue:** :ring\_buoy:/ :sos:

The AUV can pass through the gate at any depth from the floor to just below the gate. The AUV takes on the role of the sign on the side through which it passes.

Teams can gain extra points by passing through the gate with “style”. For every 90° change in orientation, the AUV increases the accumulated points. However, returning to the last previous orientation won’t count. I.e. an AUV that rolls 90° and then back to 0° would not get points. Roll and Pitch are worth more than Yaw.

#### **Capability Matrix**

Maintain depth and heading, visual identification

* **Core**: Pass through the gate.
* **Advanced**: Coin flip determines orientation of the vehicle at the start.
* **Disruptive**: Random role assignment, either by a coin flip or visual indicator. &#x20;

{% hint style="info" %}
In the event the visual indicator is not available, a coin flip will be used to randomly assign a role to the AUV before it starts its run.
{% endhint %}

#### **Scoring Quest**

* Pass through the gate
* Maintain control
* Coin flip (heading)
* Coin flip (role)
* Style: Yaw, Roll/Pitch

#### Task

<figure><img src="https://4116372859-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F26VLfALJrSNXYGtaP3Ke%2Fuploads%2FmtZ4YbTKMhTVn1o9xRRn%2FTask01_StartAssessment_02.png?alt=media&amp;token=1cc5ed54-1be6-439e-8b93-5ac03ec3bae0" alt=""><figcaption></figcaption></figure>

#### Task Elements

The table below contains descriptions of the task elements for this task. Task design files can be found in [RoboSub Data Sharing](https://robonation.app.box.com/s/pip5o8xhaqciotz09lqypp4v0txrlktk/folder/134951486128).

<table><thead><tr><th width="122">Task Element</th><th width="157">Description</th><th width="178">Color</th><th width="269">Height</th></tr></thead><tbody><tr><td>Gate</td><td>¾ in, ½ in PVC, Foam, 3 in. Box Corrugated plastic </td><td>White / Black / Red</td><td>120 in x 60 in <br>(3 m x 1.5 m)</td></tr><tr><td>Gate Divider</td><td>2" Flat plate</td><td>Red</td><td>24 in (610 mm)</td></tr><tr><td><span data-gb-custom-inline data-tag="emoji" data-code="1f9ed">🧭</span>  <span data-gb-custom-inline data-tag="emoji" data-code="2692">⚒️</span></td><td>Role: Survey &#x26; Repair </td><td>Vinyl print<br><a href="https://robonation.app.box.com/s/pip5o8xhaqciotz09lqypp4v0txrlktk/folder/350497151429">Design files</a></td><td>12 in x 12 in<br>(305 mm x 305mm )</td></tr><tr><td><span data-gb-custom-inline data-tag="emoji" data-code="1f6df">🛟</span>  <span data-gb-custom-inline data-tag="emoji" data-code="1f198">🆘</span></td><td>Role: Search and Rescue </td><td>Vinyl print<br><a href="https://robonation.app.box.com/s/pip5o8xhaqciotz09lqypp4v0txrlktk/folder/350497151429">Design files</a></td><td>12 in x 12 in<br>(305 mm x 305 mm)</td></tr></tbody></table>

## 3.2.3  Task 2 - Avoid Debris (Slalom)

Navigate a channel that is blocked with debris.

The task consists of sets of vertical <mark style="color:red;">**RED**</mark> and **WHITE** PVC pipes moored at different heights to the floor, and floating vertically. They are arranged with **WHITE** on the left, <mark style="color:red;">**RED**</mark> in the middle, and **WHITE** on the right.  There are three sets of pipes, and the AUV earns points for each set that is successfully navigated.

The AUV will obtain more points for staying on the same side of the red pipe when it passed through the gate.  I.e. if the AUV passed with the red gate divider on the right, it should pass through the Slalom with the red pipe on the right.  The AUV will obtain more points for staying within the area of the pipes (not above, not below).  As long as a part of the AUV breaks the plane of the pipes, it is considered inside. &#x20;

#### **Capability Matrix**

Adjust depth, course correction, visual perception

* **Core**: Identify and stay within the slalom
* **Advanced**: Navigate the correct side
* **Disruptive**: None

#### **Scoring Quest**

* Navigate the debris: any, correct side
* Correct depth

#### Task

<figure><img src="https://4116372859-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F26VLfALJrSNXYGtaP3Ke%2Fuploads%2FQhiLcS7nrRLbMFqp6CVs%2FTask02_AvoidDebris.png?alt=media&amp;token=b947fccc-a513-4994-8fa7-541ccd7d2987" alt=""><figcaption></figcaption></figure>

#### Task Elements

The table below contains descriptions of the task elements for this task. Task design files can be found in [RoboSub Data Sharing](https://robonation.app.box.com/s/pip5o8xhaqciotz09lqypp4v0txrlktk/folder/134951486128).

<table><thead><tr><th width="146">Task Element</th><th width="138">Description</th><th width="96">Color</th><th width="146">Height</th></tr></thead><tbody><tr><td>Pipes</td><td>1 inch PVC</td><td>White / Red</td><td>3 ft (0.9m)</td></tr></tbody></table>

## 3.2.4 Task 3 - Recon (Bins)

Recon the area to determine what assistance to provide.

This task consists of a 3D pipeline made from PVC supported off the bottom of the pool. On the sides of the pipeline are four bins. Two for the **Survey & Repair** role and two for the **Search & Rescue** role. Inside the bins will be images representing each role:

* **Survey & Repair:** :fire:
* **Search & Rescue:** :drop\_of\_blood:

Near each bin on the pipeline will be a light and a magnetic detector for the AUV to interact with. At the start of a run, the light will be turned on signaling the need for repair or rescue.

The AUV will obtain points for dropping up to two (2) markers into the bin, based on where a marker finally comes to rest. More points are awarded for dropping a marker in each of the bins corresponding to the AUV's role, one marker in each of the two bins. Additional points are awarded for interacting with up to two (2) magnetic detectors on the pipeline and turning the lights off.

{% hint style="info" %}
**Now Available |** [**Build Guide: Underwater Magnetically Activated Light**](https://app.gitbook.com/o/vIeCJcHxnpg20jk4GeP2/s/26VLfALJrSNXYGtaP3Ke/~/edit/~/changes/17/section-3-autonomy-challenge/3.2-task-descriptions/build-guide-underwater-magnetically-activated-light)
{% endhint %}

#### **Capability Matrix**

Station keep (horizontal), Visual identification, (maybe) Interaction

* **Core**: Drop markers in the bin
* **Advanced**: Drop markers in the correct bin
* **Disruptive**: Interact with magnet to turn off light

#### **Scoring Quest**

* Drop marker(s) in: any, correct bin
* Turn off light

#### Task

<figure><img src="https://4116372859-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F26VLfALJrSNXYGtaP3Ke%2Fuploads%2FqKsKFi2wXLSc5Q7kWmr7%2FTask03_Recon.png?alt=media&amp;token=fb40c62c-5cc4-464c-aaee-cbf02d9c768a" alt=""><figcaption></figcaption></figure>

#### Task Elements

The table below contains descriptions of the task elements for this task. Task design files can be found in [RoboSub Data Sharing](https://robonation.app.box.com/s/pip5o8xhaqciotz09lqypp4v0txrlktk/folder/134951486128).

<table><thead><tr><th width="124">Task Element</th><th width="138">Description</th><th width="269">Base Dimensions</th></tr></thead><tbody><tr><td>Bin</td><td>Bin with insert</td><td>CleverMade Collapsible Milk Crate 25L (Amazon)</td></tr><tr><td><span data-gb-custom-inline data-tag="emoji" data-code="1f525">🔥</span>   <span data-gb-custom-inline data-tag="emoji" data-code="1fa78">🩸</span></td><td>Vinyl Print<br><a href="https://robonation.app.box.com/s/pip5o8xhaqciotz09lqypp4v0txrlktk/folder/350497151429">Design files</a></td><td>12 in x 12 in<br>(305 mm x 305 mm)</td></tr><tr><td>Magnetically Activated Light</td><td><a href="https://app.gitbook.com/o/vIeCJcHxnpg20jk4GeP2/s/26VLfALJrSNXYGtaP3Ke/~/edit/~/changes/17/section-3-autonomy-challenge/3.2-task-descriptions/build-guide-underwater-magnetically-activated-light">Build Guide</a></td><td></td></tr></tbody></table>

## 3.2.5 Task 4 - Deploy (Torpedoes)

Provide necessary assistance.

This task consists of one vertical board with images on the front side, :fire::fire\_engine: for **Survey & Repair** and :drop\_of\_blood::ambulance: for **Search & Rescue.** There are two different versions of the board.  There are two different size openings.

Points are awarded for firing torpedoes through any opening. A torpedo must pass through the opening for full points. Partial points are awarded if the torpedo touches the board without passing through. Maximum points are awarded for firing a torpedo through the larger opening (:fire: :drop\_of\_blood:) and then the smaller opening (:fire\_engine: :ambulance:).  Additional points are awarded for firing torpedoes further away from the board: far (1 ft, 0.3m) and farther (1.5 ft, 0.46m).&#x20;

#### **Capability Matrix**

Acoustic localization, station keep (horizontal/vertical), visual identification

* **Core**: Fire torpedo through any opening
* **Advanced**: Fire torpedoes through opening in the correct sequence (large, small)
* **Disruptive**: None

#### **Scoring Quest**

* Fire torpedo through any opening
* Fire torpedo through correct sequence
* Fire from far, farther

#### Task

<figure><img src="https://4116372859-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F26VLfALJrSNXYGtaP3Ke%2Fuploads%2FWAusz5rjqC6Q8j6HCLrv%2FTask04_Depoy02.png?alt=media&amp;token=30437754-ca70-46a1-a55f-1e9a8a9b9d91" alt=""><figcaption></figcaption></figure>

#### Task Elements

The table below contains descriptions of the task elements for this task. Task design files can be found in [RoboSub Data Sharing](https://robonation.app.box.com/s/pip5o8xhaqciotz09lqypp4v0txrlktk/folder/134951486128).

<table><thead><tr><th width="156">Task Element</th><th width="244.655517578125">Description</th><th width="183">Base Dimensions</th></tr></thead><tbody><tr><td><span data-gb-custom-inline data-tag="emoji" data-code="1f525">🔥</span>  <span data-gb-custom-inline data-tag="emoji" data-code="1f692">🚒</span><br><br><span data-gb-custom-inline data-tag="emoji" data-code="1fa78">🩸</span>  <span data-gb-custom-inline data-tag="emoji" data-code="1f691">🚑</span></td><td>Vinyl print images and openings, Corrugated plastic backing<br><a href="https://robonation.app.box.com/s/pip5o8xhaqciotz09lqypp4v0txrlktk/folder/350497151429">Design files</a></td><td>2 ft x 2 ft<br>(0.6m x 0.6m)<br></td></tr></tbody></table>

## 3.2.6 Task 5 - Restore (Octagon)

Restore vital infrastructure and health.

A 9 ft (2.7m) diameter octagon floats on the surface and an acoustic pinger, located on the floor near the center of the octagon, guides the AUV to this task. Hanging from the octagon, facing inward, are images of :compass:, :hammer\_pick:, :ring\_buoy:, and :sos:.  Located in the center of the octagon is the Resupply table. On the table are two different items for each role: **Survey & Repair** has :nut\_and\_bolt:and:electric\_plug:; **Search & Rescue** has :pill:and :adhesive\_bandage:. Along two opposite edges is a basket to place the items.  At the bottom of the **Survey & Repair** basket is :warning: and at the bottom of the **Search & Rescue** is :helmet\_with\_cross:.

Points are awarded for surfacing inside the octagon and for surfacing with each item (stay inside the octagon to continue your run). Points are awarded for facing any image hanging from the octagon, with maximum points for facing the correct icon based on the role and items in the basket. With one item in the basket face :compass:or :ring\_buoy:. With two (or more) items in the basket face :hammer\_pick:or :sos:.  Points are awarded for moving the items to any of the baskets. Maximum points are awarded for placing the correct items in their corresponding basket based on role.

Extra points are awarded for the AUV vehicle rotating the same number of turns as the items collected in the baskets. (i.e. three items in the basket? rotate three times.)

#### **Capability Matrix**

Acoustic localization, station keep (horizontal/vertical), visual identification, manipulation

* **Core**: Surface in octagon
* **Advanced**: Pick up and deliver at least one object to any basket
* **Disruptive**: Face correct image

#### **Scoring Quest**

* Surface in area
* Surface with object
* Drop object
* Place object in any / correct basket
* Yaw correct number of times for object in basket
* Face any image / correct image
  * Correct image is dependent on number of objects in basket
    * 1 item, point to : :compass:or:ring\_buoy:
    * 2 item, point to : :hammer\_pick:or:sos:

#### Task

<figure><img src="https://4116372859-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F26VLfALJrSNXYGtaP3Ke%2Fuploads%2FwTPveVtc9PQmRlEjvmTn%2FTask05_Restore02.png?alt=media&amp;token=227c3b50-5247-442e-acbd-eafcb1869b52" alt=""><figcaption></figcaption></figure>

#### Task Elements

The table below contains descriptions of the task elements for this task. Task design files can be found in [RoboSub Data Sharing](https://robonation.app.box.com/s/pip5o8xhaqciotz09lqypp4v0txrlktk/folder/134951486128).

<table><thead><tr><th width="156">Task Element</th><th width="270.655517578125">Description</th><th width="280">Base Dimensions</th></tr></thead><tbody><tr><td>Octagon</td><td>½ in PVC Surface marker</td><td>9 ft diameter<br>(2.7 m)</td></tr><tr><td>Images</td><td>Vinyl print<br><a href="https://robonation.app.box.com/s/pip5o8xhaqciotz09lqypp4v0txrlktk/folder/350497151429">Design files</a></td><td>12 in x 12 in<br>(305 mm x 305mm)</td></tr><tr><td>Table</td><td>½ in PVC Table containing samples and collection bins</td><td>2 ft x 2 ft<br>(0.6 m x 0.6 m)</td></tr><tr><td>Objects </td><td>Cylindrical and Box-like objects to pick up with images on the top</td><td><ul><li>Loretoy 4oz plastic jars with lids (2.76" dia x 1.97" tall)</li><li>Satinior small clear plastic bead storage container (3.3 x 3.3 x 1.2")</li></ul></td></tr><tr><td>Basket</td><td>Collection baskets</td><td>Netany Plastic Storage Baskets (Amazon)</td></tr></tbody></table>

## 3.2.7 Task 6 - Return Home

At the end of the run, while underwater, the AUV passes back through the start gate.

## 3.2.8 Path

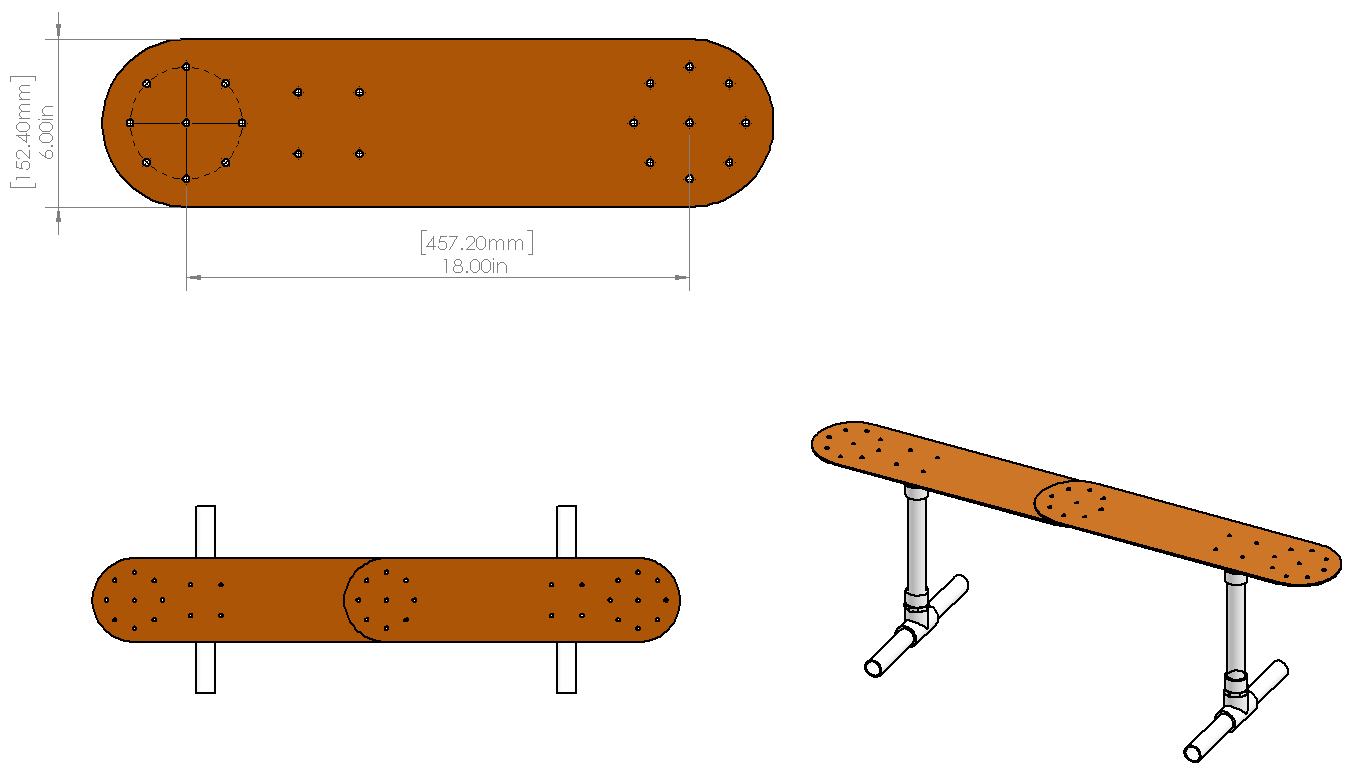
The path markers are \~4 feet (\~1.2m) long by 6 in (15 cm) wide.  The Path is colored <mark style="color:orange;">**ORANGE**</mark>. Each path markers is placed directly after the current task and points to the next task.  The path is a straight segment.  No points are awarded for following the path, the path is intended to help guide the AUV to the next task.

There are two path markers to aid in navigation.  One path marker is positioned at the gate that points to the *Avoid Debris (Slalom)* task. From the *Avoid Debris*, the second path points to *Recon (Bins)*.  Those are the only path segments which can be used to visually orient the AUV to the next task.

<figure><img src="https://content.gitbook.com/content/26VLfALJrSNXYGtaP3Ke/blobs/k1F4F8vDFb4eWd4CZFR2/straightPath.PNG" alt=""><figcaption><p>Figure : Path marker</p></figcaption></figure>

## 3.2.9 Pinger

For each pinger task, the pinger is located very close to the task (sometimes next to, sometimes in the center).  No points are awarded for following/finding a pinger, the pinger is intended to help guide the AUV to the task.

There are two pingers to aid in navigation.  The first pinger is positioned at *Deploy (Torpedoes).*  The second pinger is located at *Restore (Octagon).*

See section [5.4.3 Pingers](https://robonation.gitbook.io/robosub-resources/section-3-autonomy-challenge/pages/K30gTcC4PI8vizV9WYir#id-5.4.3-pingers) for more information.